
Technical specifications
- Sensor model: EM9767P
- Operating temperature: −20 to +60 °C
- Storage temperature: −30 to +70 °C
- Ambient humidity: 60–70%
- Atmospheric pressure: 860–1060 hPa
- Sensitivity: −59 to −53 dB
- Output impedance: 2.2 kΩ
- Maximum current: 500 μA
- Signal-to-noise ratio: 55 dB
- Voltage reduction: −3 dB
- Operating voltage: 1–10 V
- Dynamic range: 100 dB
Description
The sound sensor is your robot's “ears”. It outputs an analog signal proportional to the loudness of surrounding sounds.
Use
Connection
The sensor uses a standard 3-pin connector and connects to any IN port on Trackduino.
Programming
The required blocks are in the “Sensors” block group.
| Block and generated function | Description |
|---|---|
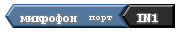 int micAnalog(int port) | Returns a value from 0 to 1023 corresponding to the loudness of the sound received. Argument: int port — the port the sensor is connected to. |
The threshold microphone block  does not work with this sensor; it is intended for the digital microphone.
Project example
Noise level meter
Generated code:
int _ABVAR_1_SoundLevel = 0 ;

void setup()
{
  pinMode( OUT1 , OUTPUT );
  pinMode( OUT2 , OUTPUT );
  pinMode( OUT3 , OUTPUT );
}

void loop()
{
  _ABVAR_1_SoundLevel = micAnalog(IN1) ;
  if (( ( _ABVAR_1_SoundLevel ) > ( 25 ) ))
  {
    led ( OUT1 , HIGH );
    if (( ( _ABVAR_1_SoundLevel ) > ( 50 ) ))
    {
      led ( OUT2 , HIGH );
      if (( ( _ABVAR_1_SoundLevel ) > ( 75 ) ))
      {
        led ( OUT3 , HIGH );
      }
    }
  }
  else
  {
    led ( OUT1 , LOW );
    led ( OUT2 , LOW );
    led ( OUT3 , LOW );
  }
}