
Specifications
- Sensor resistance when straight: 10 kΩ ±30%.
- Sensor resistance when bent: 60–110 kΩ.
- Nominal power: 0.5 W.
- Peak power: 1 W.
- Flex life: more than 1 million cycles.
- Operating temperature: −35 to +80 °C.
- Flexible section dimensions (L × W): 100 × 6.35 mm.
The sensor circuit has a trimmer resistor used to set the circuit’s output zero point.
Overview
A strain gauge is a resistor whose resistance changes when it is deformed. Strain gauges are used in strain measurement to measure deformation in mechanically coupled components. They are a core part of strain sensors used to indirectly measure force, pressure, weight, mechanical stress, torque, and other quantities.
Applications
The sensor can be used to:
- Measure angles and displacement.
- Analyze bending to infer a device’s physical state or movement.
When the strain gauge’s conductive elements are stretched, they become longer and thinner, increasing resistance. Compression decreases resistance.
Connecting
The sensor uses a standard 3-pin connector and plugs into any IN port on the Trackduino controller.
Programming
The sensor block is in the Sensors block group.
| Block and generated function | Description |
|---|---|
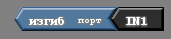 int bend(int port) | Returns a value from 0 to 1023 corresponding to the resistance level.int port: port connected to the sensor. |
Example project
Controlling a servomotor
Generated code:
#include <Servo.h>

Servo servo_port_OUT1;

void setup()
{
  servo_port_OUT1.attach(OUT1, BIG_SERVO);
}

void loop()
{
  servo_port_OUT1.write( ( bend(IN1) / 10 ) ); // map resistance readings to the servomotor angle
  // Dividing by 10 keeps the rotation angle between 0 and 102 degrees.
}