
Specifications
- Voltage: 4.75–5.25 V.
- Operating angle: 10°–170°.
- Service life: 100,000 tilts.
Overview
The tilt sensor contains a metal ball that rolls inside a metal housing. When tilted, the ball rolls to one side and closes the circuit. The sensor detects whether it is tilted in a direction, but does not measure the angle.
For precise tilt-angle measurements across multiple axes, use the position sensor, which is based on an accelerometer and gyroscope.
Using the sensor
Connecting
The sensor uses a standard 3-pin connector and plugs into any IN port on the Trackduino controller.
Programming
The Tilt block is in the Sensors block group. Since the sensor works like a button, it is read with the standard digitalRead() function.
| Block and generated function | Description |
|---|---|
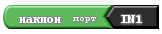 bool digitalRead(int port) | Returns TRUE when the sensor is tilted.int port: port connected to the sensor. |
Example project
Rolling LED
Generated code:
void setup()
{
  pinMode( IN1 , INPUT);
  pinMode( OUT1 , OUTPUT );
  pinMode( OUT2 , OUTPUT );
}

void loop()
{
  if (digitalRead(IN1))  // if the sensor tilts left,
  {
    led ( OUT1 , HIGH ); // turn on the left LED
    led ( OUT2 , LOW );  // and turn off the right one
    delay( 1000 );
  }
  else // otherwise (if tilted right)
  {
    led ( OUT1 , LOW );  // turn off the left LED
    led ( OUT2 , HIGH ); // and turn on the right one
    delay( 1000 );
  }
}