
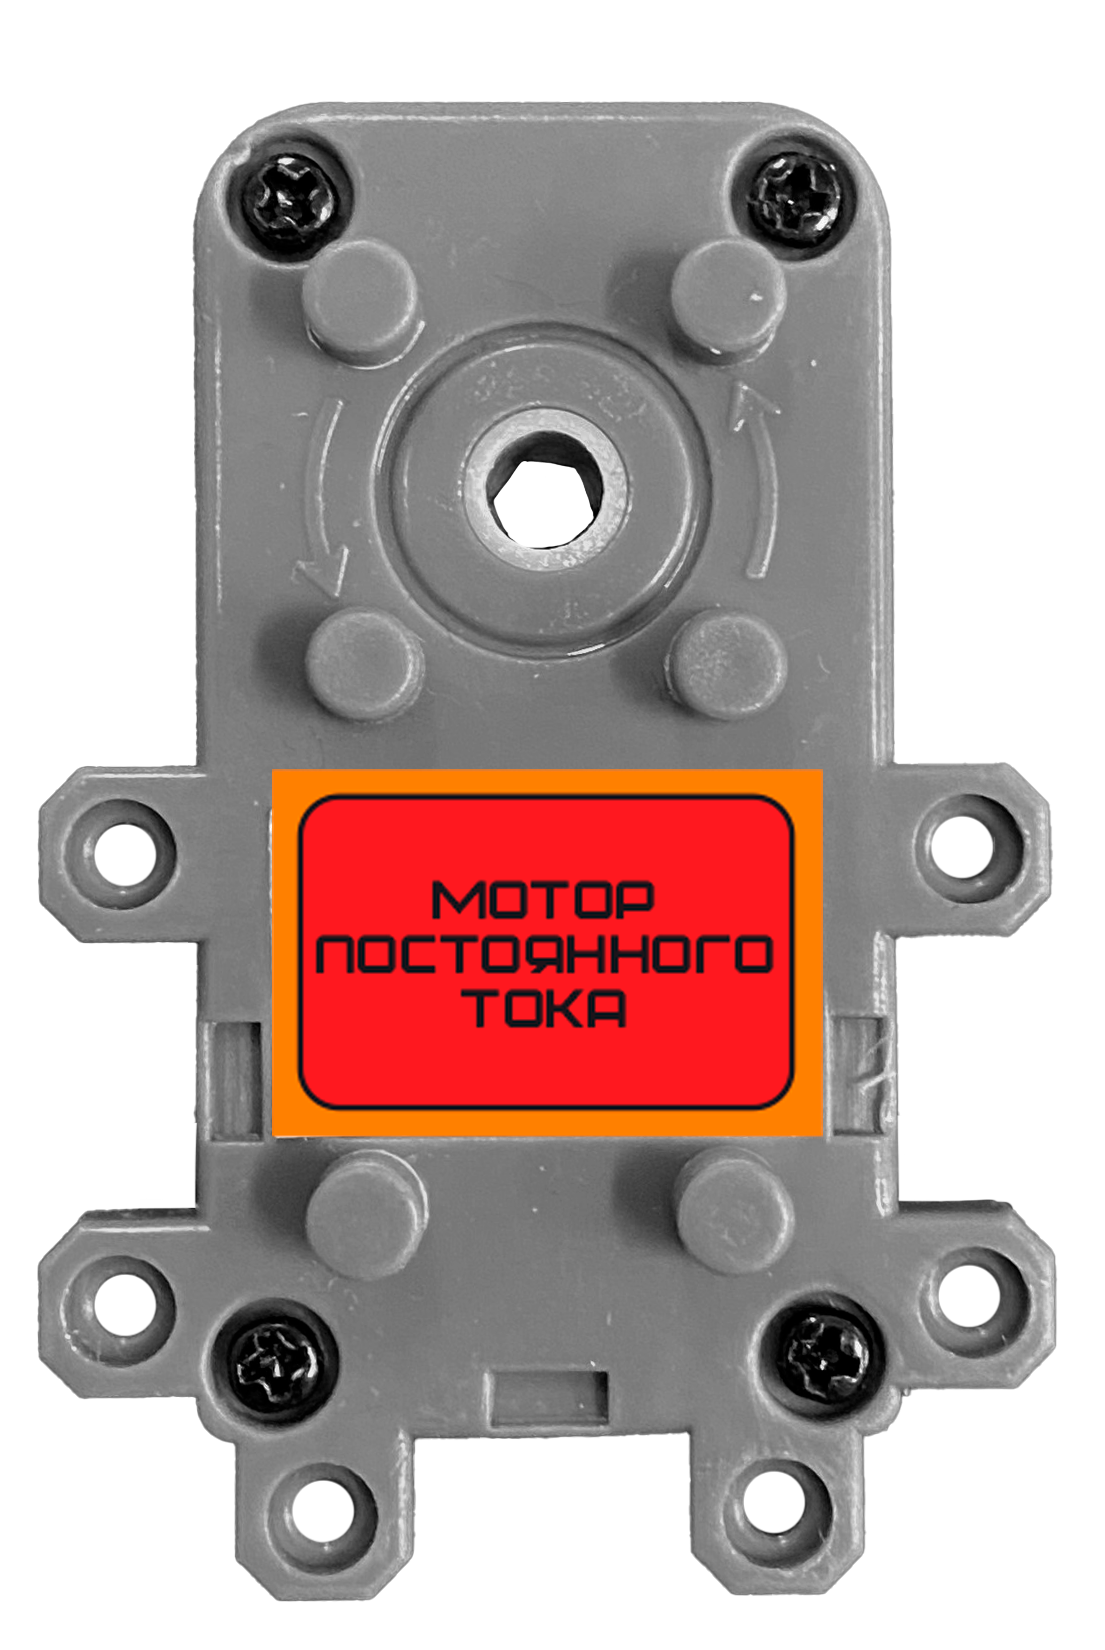
1. TECHNICAL SPECIFICATIONS
- Control: automatic phase adjustment.
- Operating voltage: 5.5–9 V.
- Operating temperature range: -20 °C to 60 °C.
- Rotational speed: 270 rpm at 9 V.
- Torque: 2.7 kgf·cm ±15% at 5.5 V / 3.5 kgf·cm ±15% at 9 V.
- Operating angle: 360°.
- Operating current: 80–110 mA.
- Connector cable length: 240 mm.
DC motor (small motor)
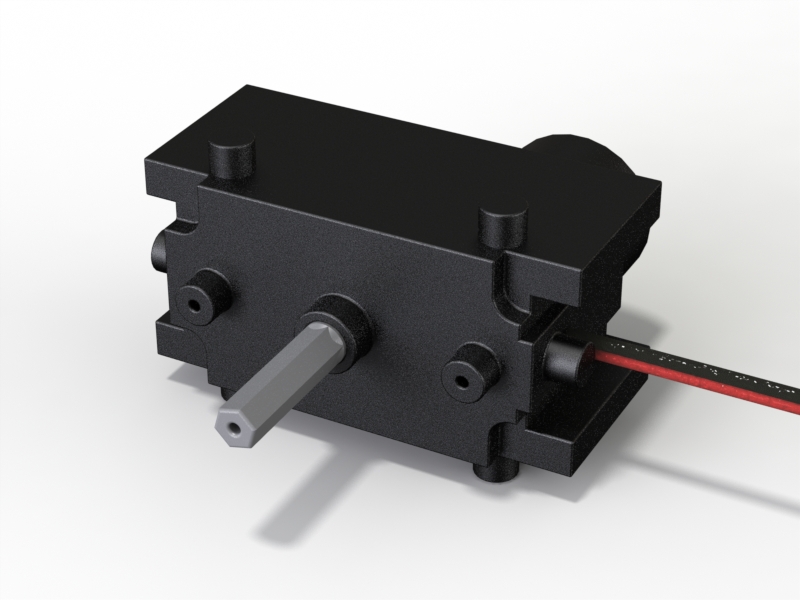
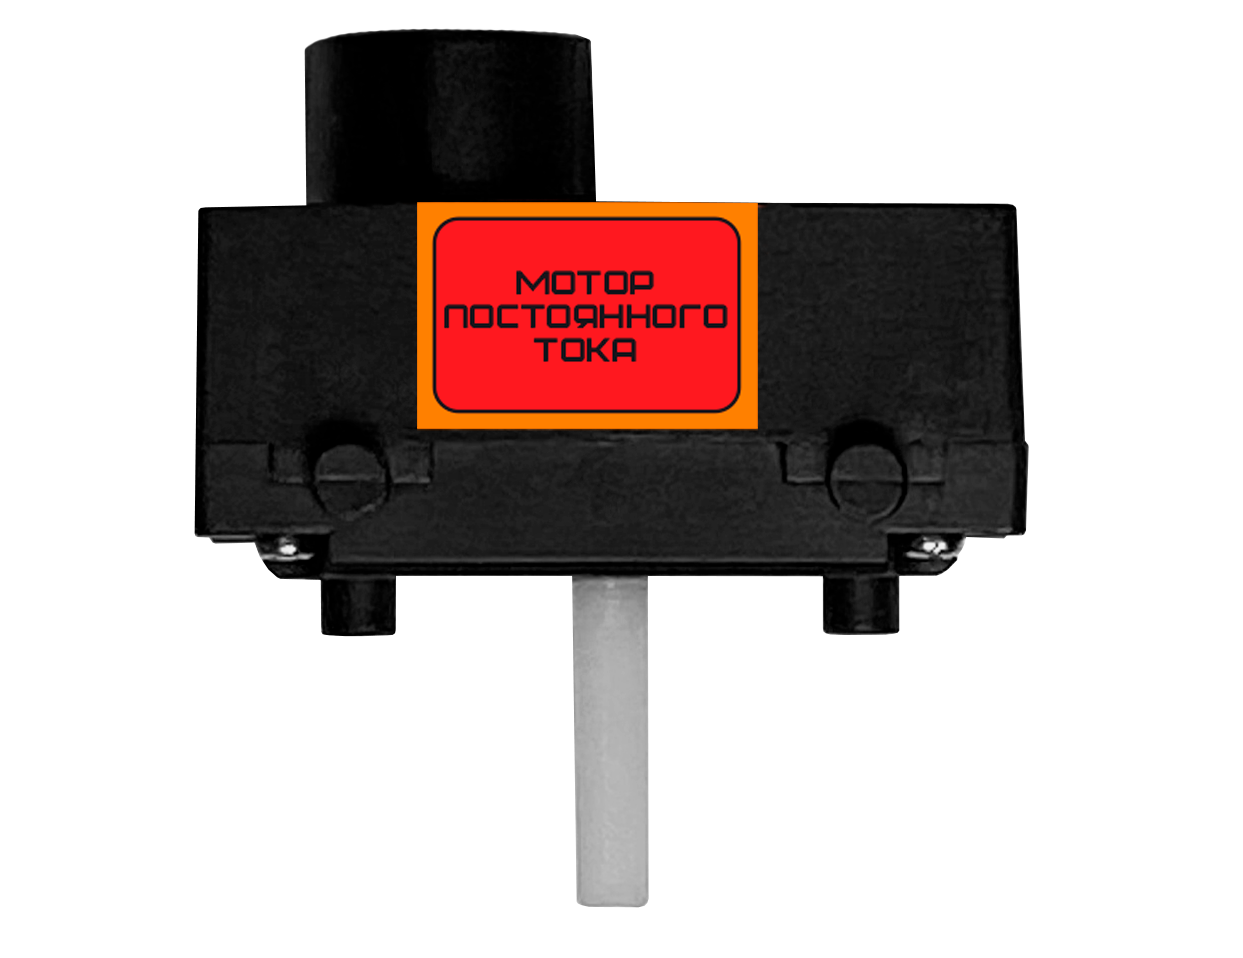
TECHNICAL SPECIFICATIONS
- Operating voltage: 3.5–6 V.
- Rotational speed: 540 rpm at 9 V.
- Load current: 170 mA.
- Torque: 2.1 kgf·cm ±15% at 5 V.
Description
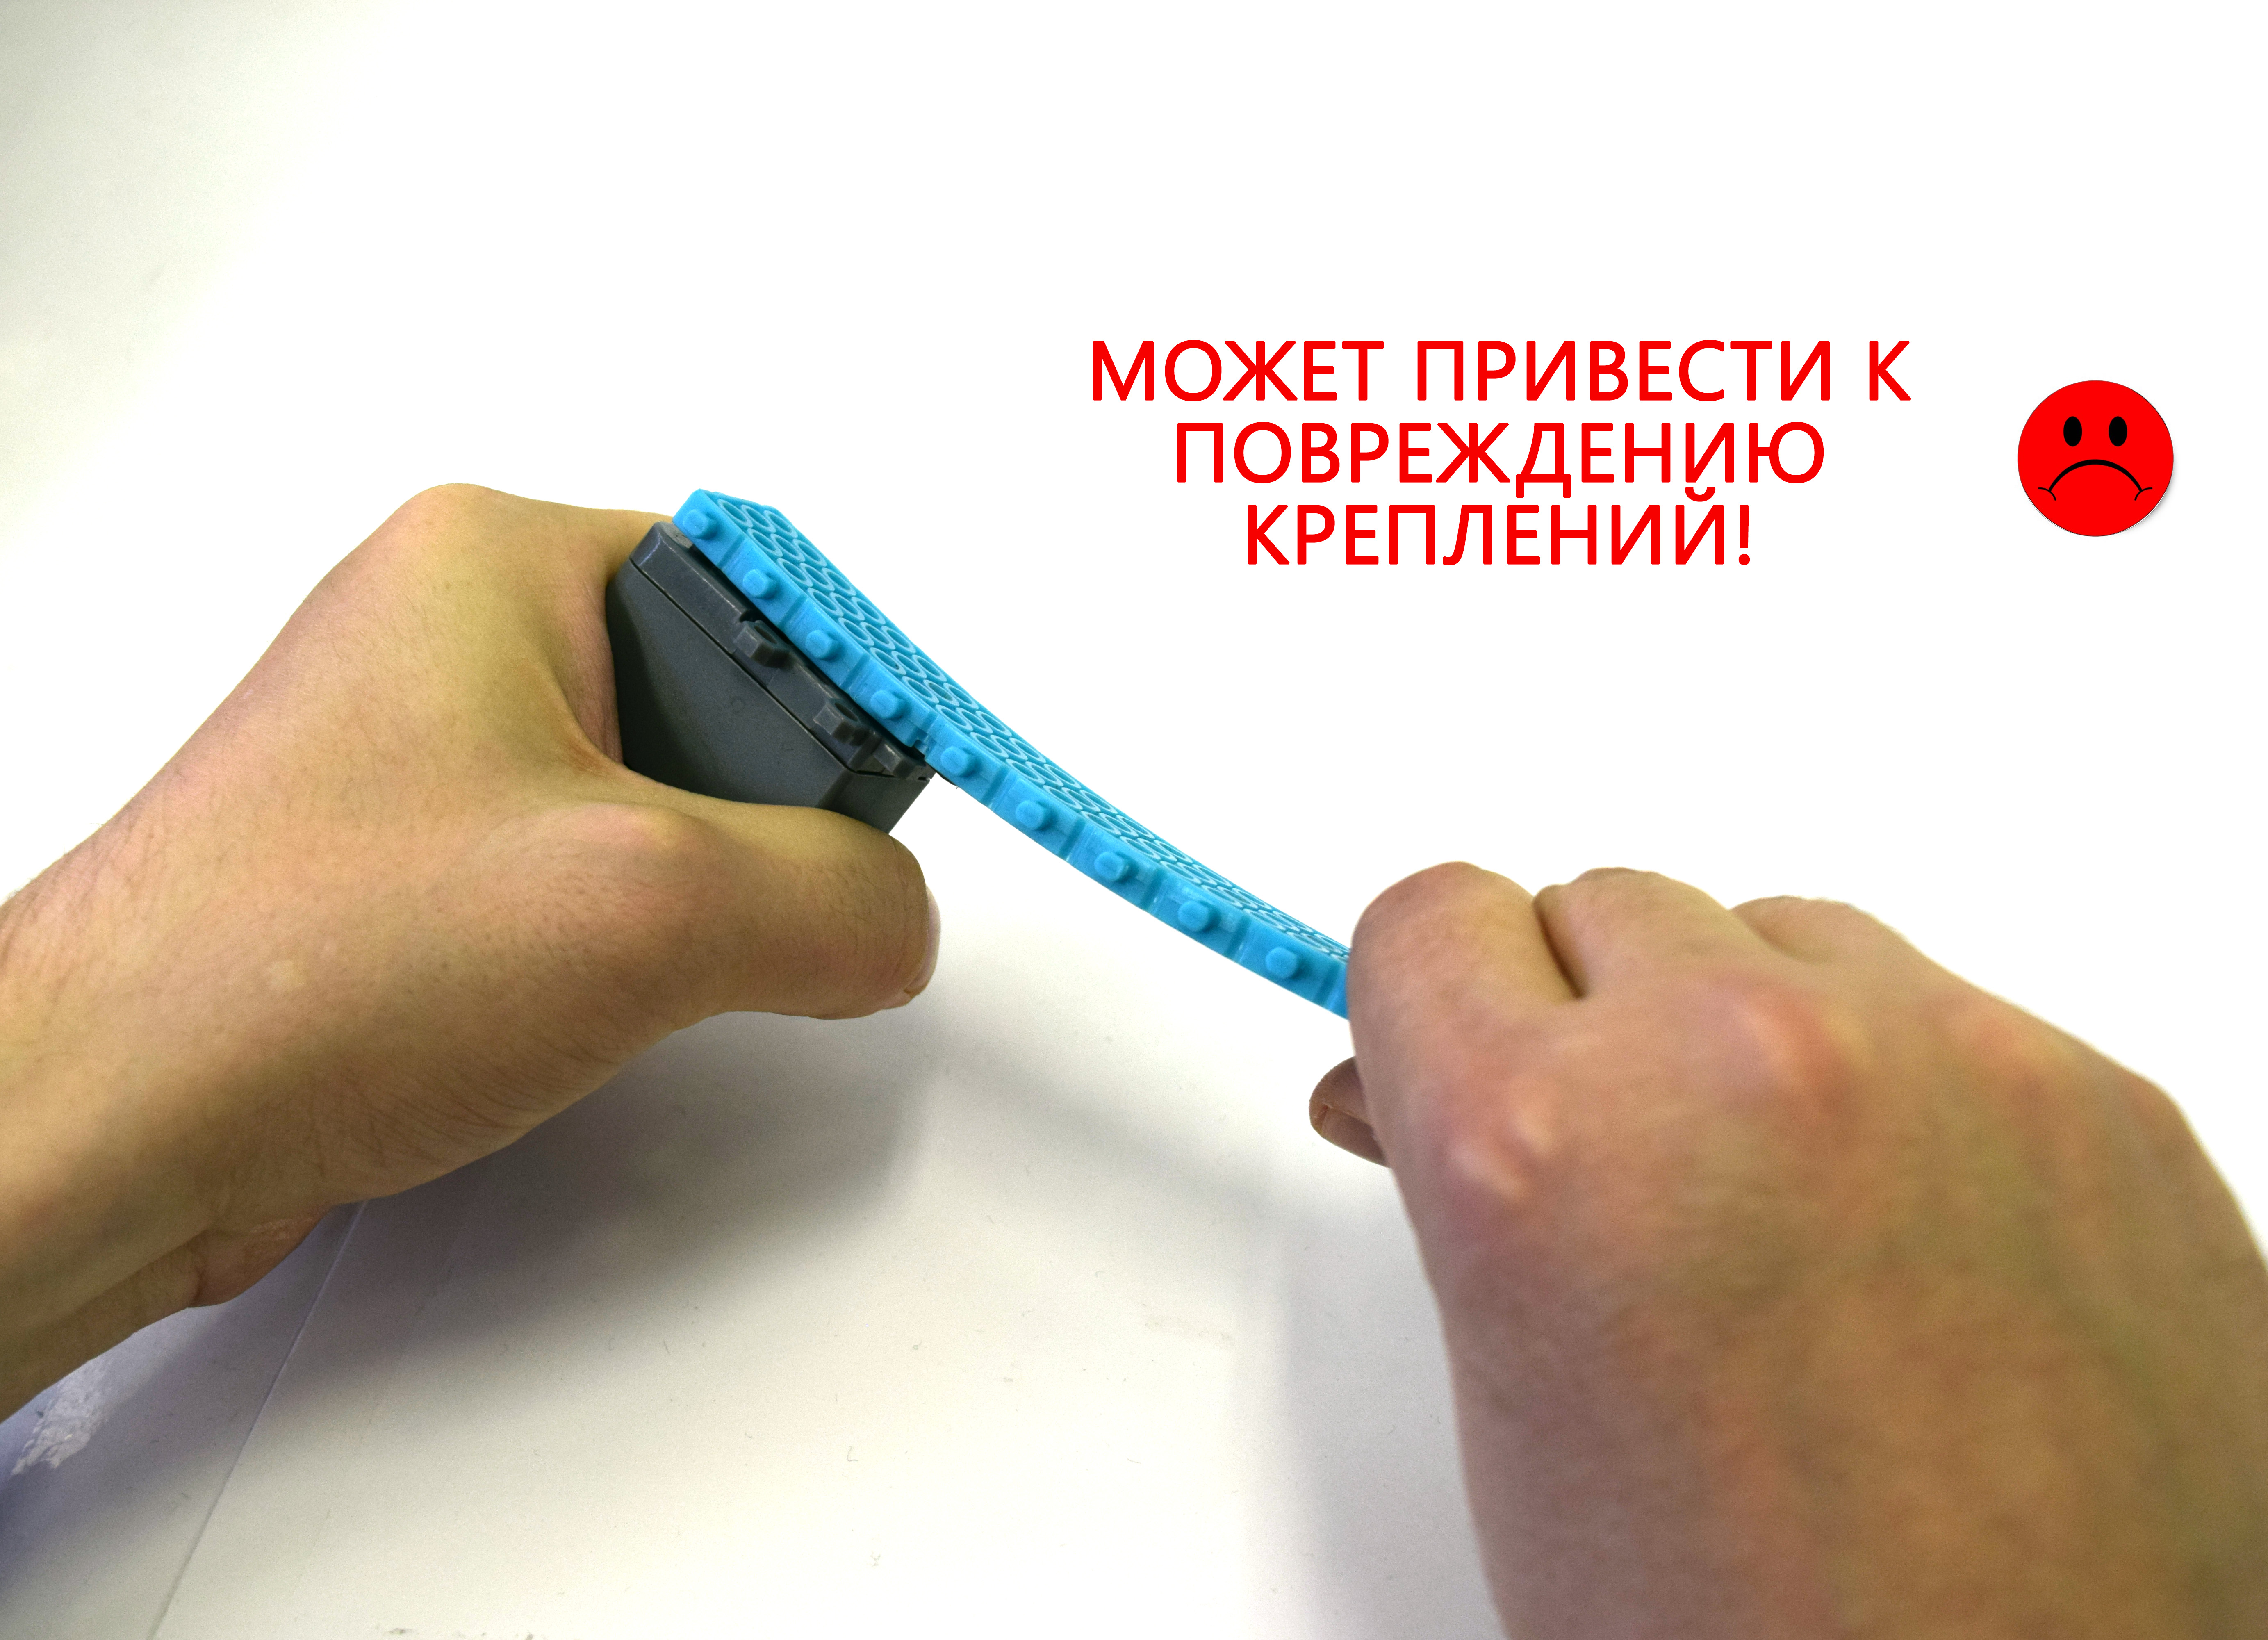
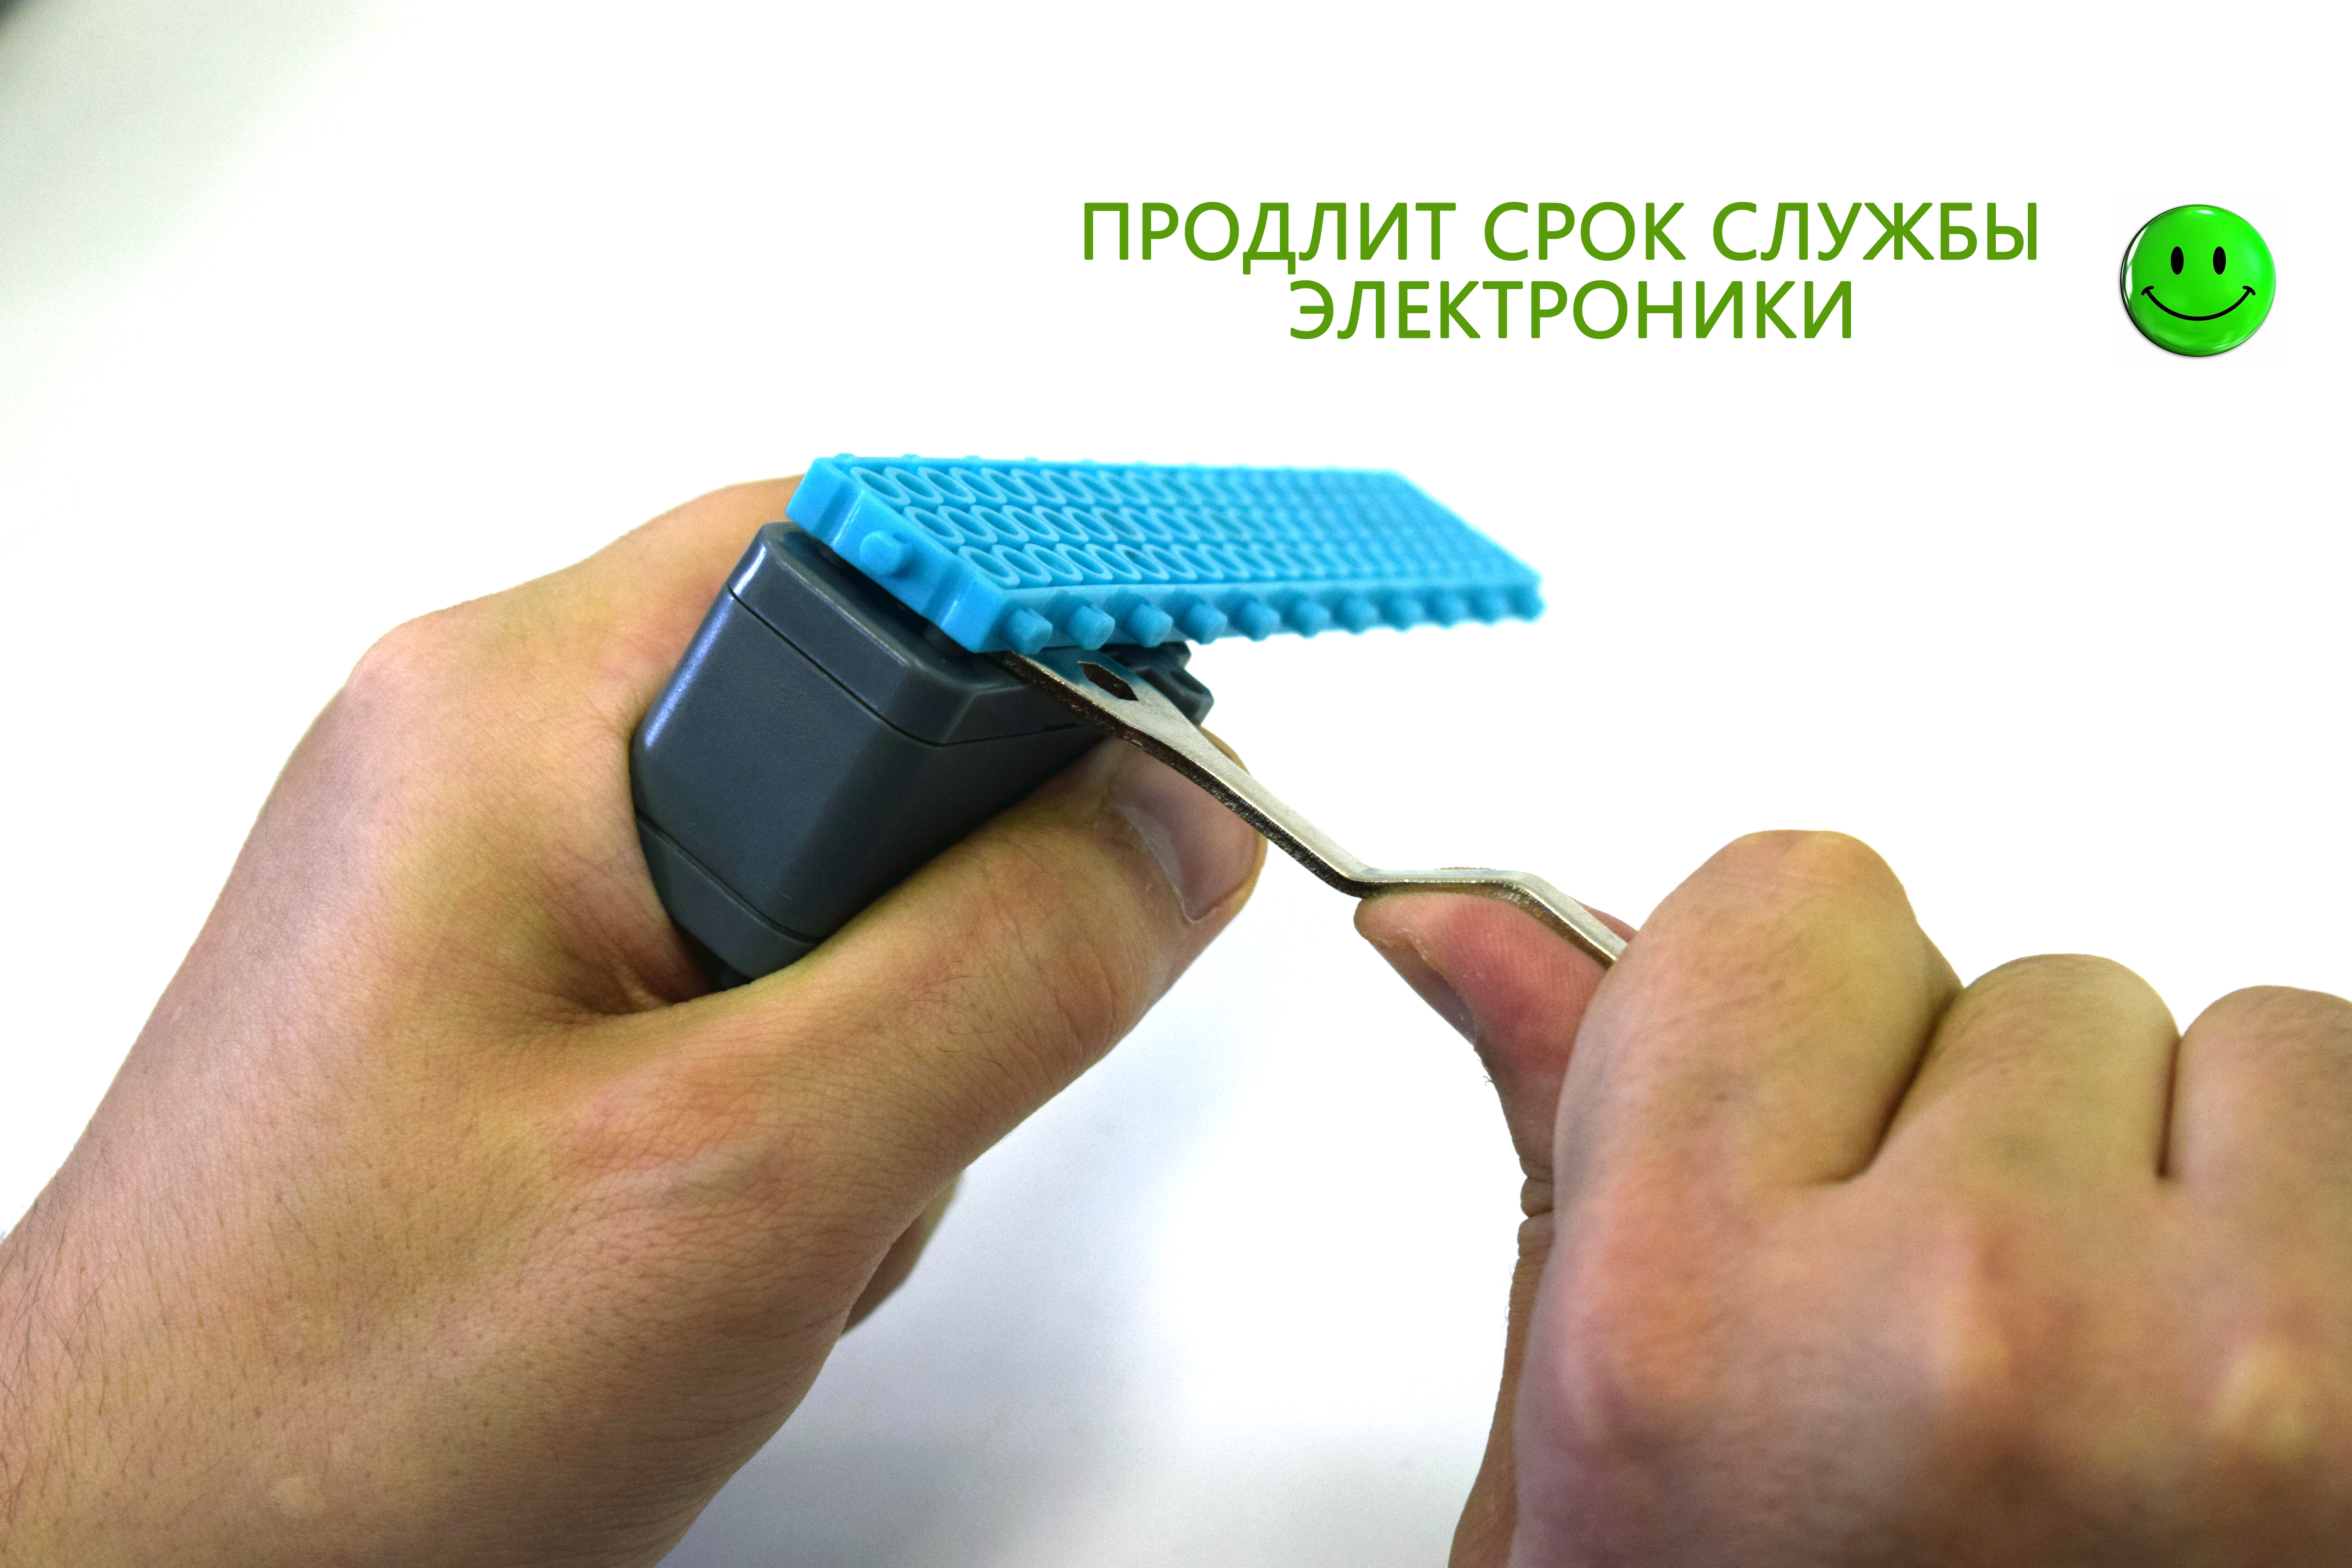
When disassembling a construction that uses a DC motor, use a wrench to detach the parts so the electronics remain in good condition.
A motor is an electrical machine (an electromechanical converter) that transforms electrical energy into mechanical energy, with heat produced as a by-product.
Operating principle:
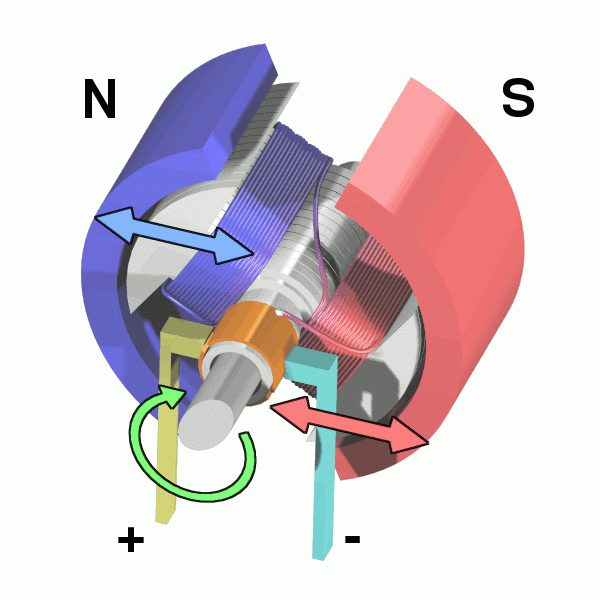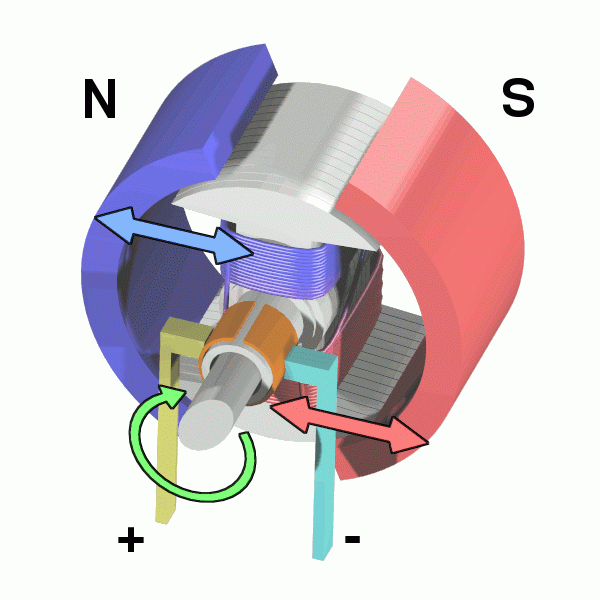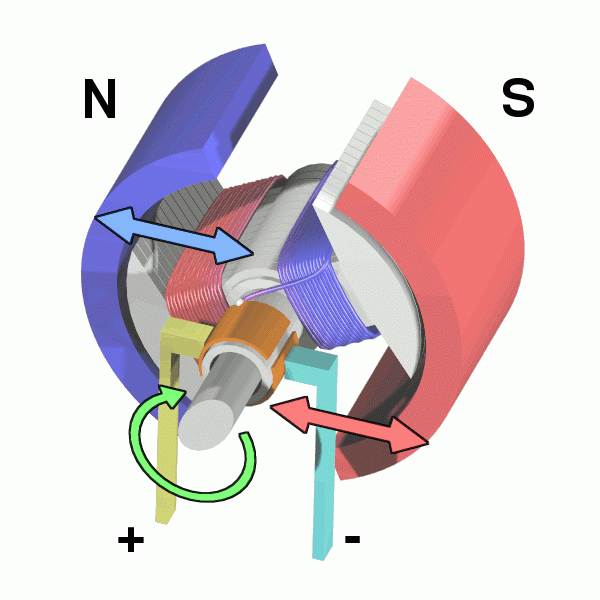
An electric motor works on the principle of electromagnetic induction. A DC motor consists of a stationary part, the field system, and a moving part, the armature. Permanent magnets serve as the field system.
Connection
The motor uses a standard 2-pin connector and can be connected to any motor port on the Trackduino controller.
The large motor has two bus connectors on the motor itself. They are identical and connected to each other, so either one can be used. These ports can also be used to connect several motors in series so that they move synchronously while using a single controller port. A cable for this connection is not included.
Programming
The Start motor, Stop motor, and Brake motor blocks are in the Motors block group.
| Block and generated function | Description |
|---|---|
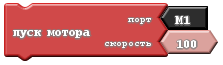 startMotor(int portM, speed); | Starts the motor on port M at the specified speed. Arguments: int portM — port connected to the motor; speed — motor speed from -100 to 100. |
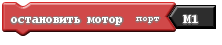 stopMotor(int portM); | Stops the motor on port M. Argument: int portM — port connected to the motor. |
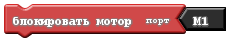 stopMotorHard(int portM); | Brakes the motor on port M. Argument: int portM — port connected to the motor. |
Project example
Night watchman
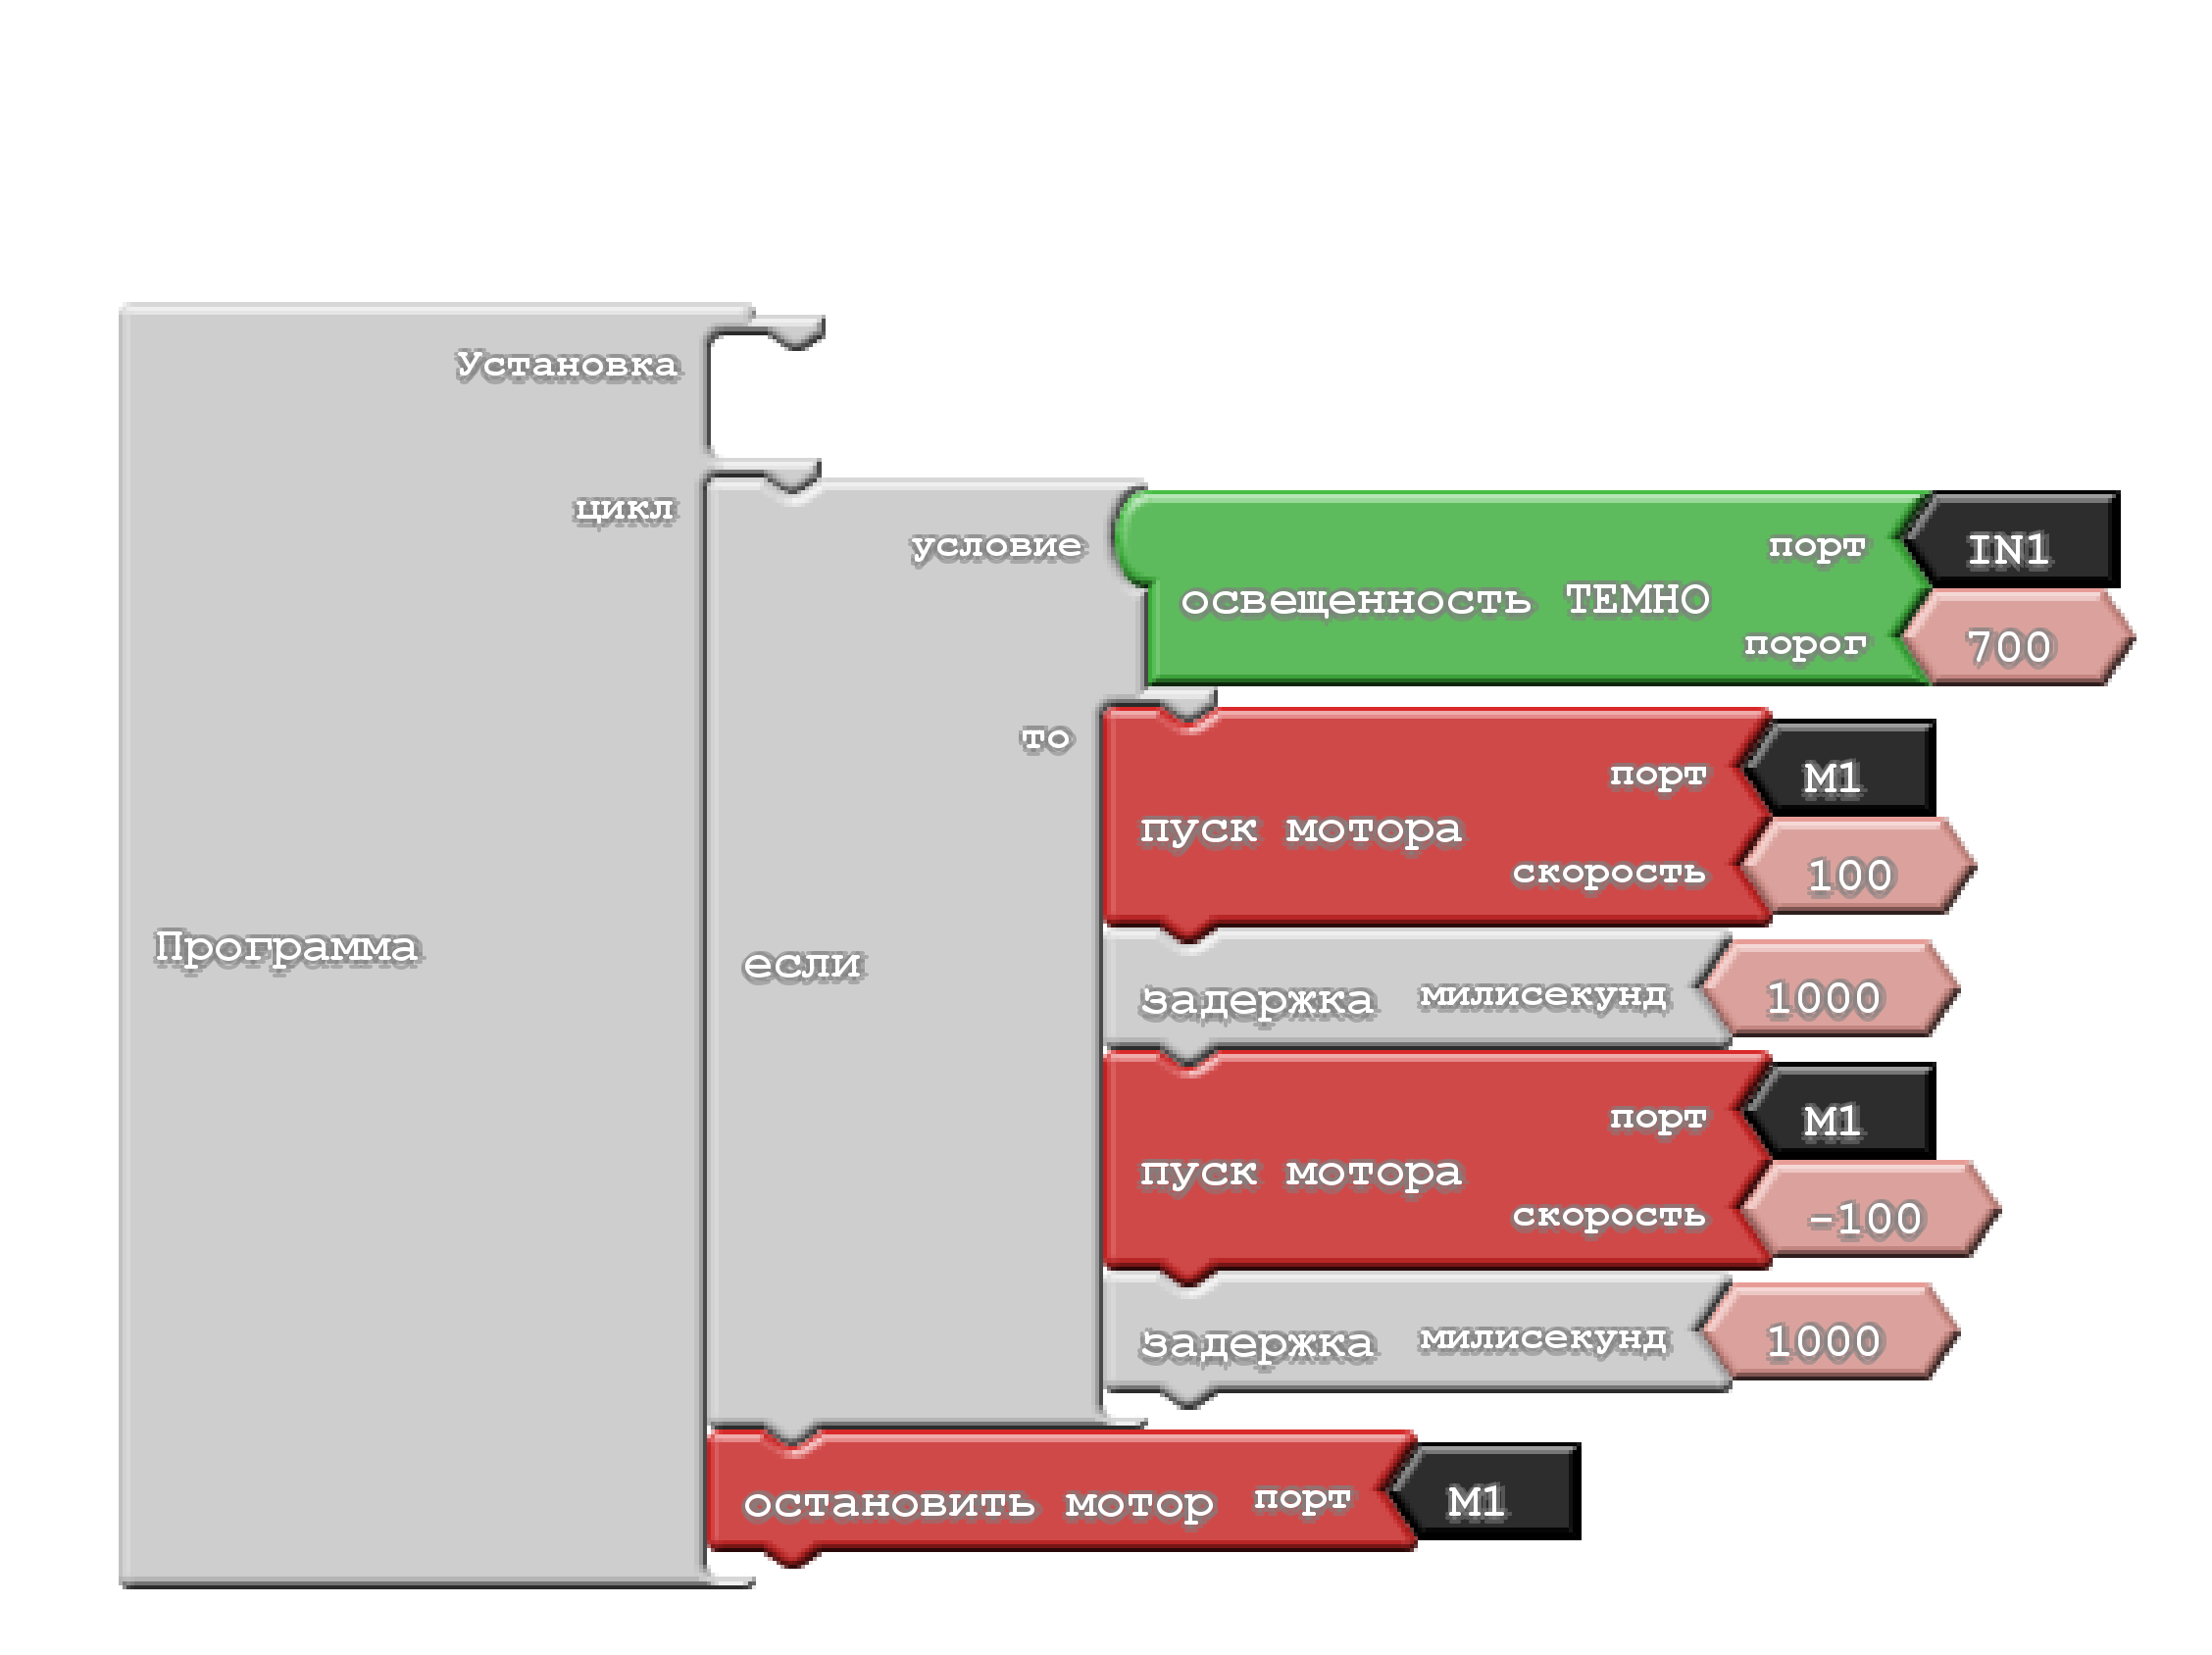
Generated code:
void setup()
{
}

void loop()
{
  if (cdsDark(IN1, 700))
  {
    startMotor(1, 100);
    delay( 1000 );
    startMotor(1, -100);
    delay( 1000 );
  }
  stopMotor(1);
}