
Specifications
- Material: GaAsP/GaAlInP (gallium arsenide phosphide / gallium aluminum indium phosphide).
- Lens type: “water”.
- Maximum operating range specified at Ta = 25°C.
- Voltage range: 1.1–1.5 V.
- Operating temperature: −40°C to +85°C.
- Peak wavelength: 940 nm.
- Maximum current consumption: 10 μA.
- Power dissipation: 80 mW.
- Radiant intensity: 5–15 mW/sr.
- Viewing angle: 30°.
- Recommended current: 20 mA.
Overview
The infrared sensor estimates distance to surfaces that reflect light well. It is useful for detecting a black line or obstacles.
How it works: The sensor contains an infrared LED that continuously emits infrared light and a photodetector sensitive to infrared radiation. When a reflective surface is nearby, some emitted light returns to the photodetector. The closer and whiter the surface, the more light returns and the higher the sensor reading.
To check whether the infrared LED works, look at the sensor through a camera, such as a phone camera.
Using the sensor
Connecting
The sensor uses a standard 3-pin connector and plugs into any IN port on the Trackduino controller.
Programming
The sensor blocks are in the Sensors block group.
| Block and generated function | Description |
|---|---|
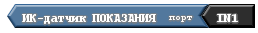 int irAnalog(int port) | Returns a value from 0 to 1023 corresponding to the amount of reflected light received.int port: port connected to the sensor. |
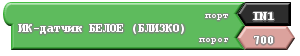 int irWhite(int port, int threshold) | Returns TRUE when the received light level is above the threshold.int port: connected port.int threshold: threshold from 0 to 1023. |
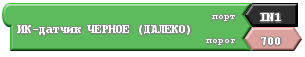 int irBlack(int port, int threshold) | Returns TRUE when the received light level is below the threshold.int port: connected port.int threshold: threshold from 0 to 1023. |
Example project
Following a black line
Generated code:
void setup()
{
}

void loop()
{
  if (irBlack(IN1, 500))
  {
    stopMotor(1);
    startMotor(2, 40);
  }
  else
  {
    startMotor(1, 40);
    stopMotor(2);
  }
}